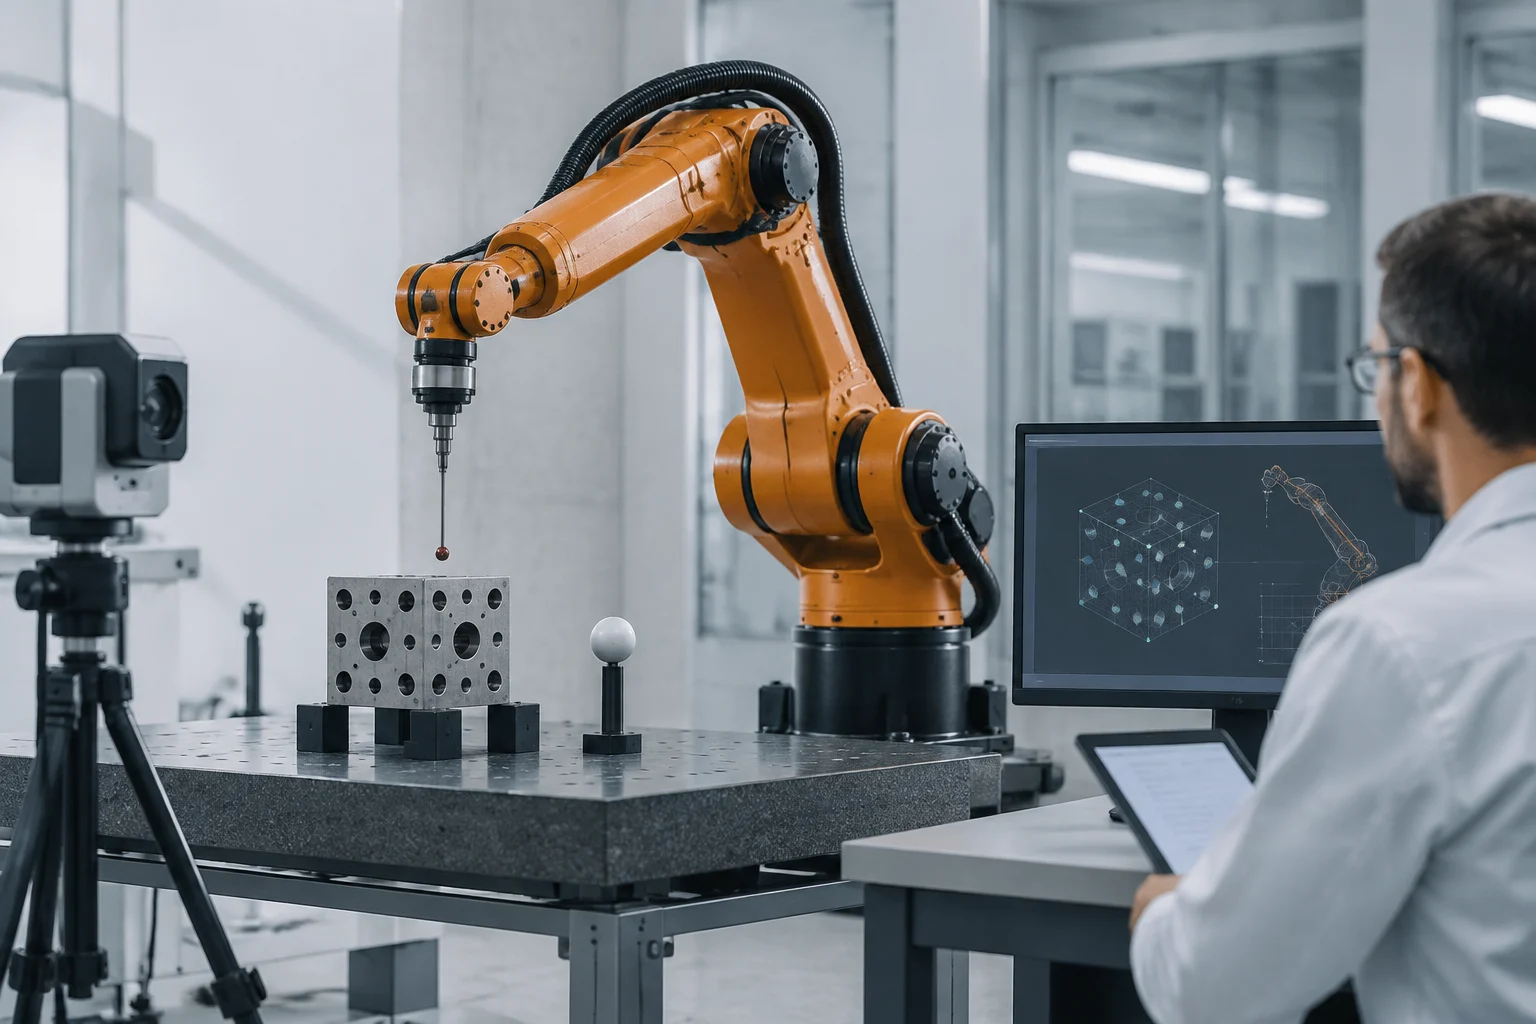
A reference for comparison, not a universal figure
Industrial robot datasheets may include figures for accuracy or repeatability, but a number on its own does not explain what was evaluated or under what conditions. ISO 9283:1998 establishes performance criteria and test methods for industrial manipulating robots. ISO’s page identifies this edition as published and notes that it was reviewed and confirmed in 2021. That describes the standard’s editorial status; it does not automatically make every figure that cites it a complete description of the robot’s behaviour.
The useful question is not only what a specification says, but which characteristic it represents. A pose measurement and a path measurement do not answer the same question, even if both are expressed as performance values. To compare datasheets, find out the parameter name, the cited edition, and which test was applied. Citing a standard provides context, but does not by itself show that two results were obtained equivalently or that they are suitable for the same process.
This distinction matters when comparing models. If one datasheet highlights a value and another reports a different parameter, ranking them by their figures does not establish which one better meets a particular need. Even when both cite the same standard, it is still necessary to know what was measured. The standard is therefore a starting point for interpreting data and asking follow-up questions, not a label that makes all specifications interchangeable.
Characteristics covered by ISO 9283
The set of characteristics associated with ISO 9283 includes pose accuracy and repeatability, multi-directional variation of pose accuracy, distance accuracy and repeatability, stabilization time, overshoot, and pose drift. It also lists path-related parameters, including path accuracy and repeatability, velocity, and cornering deviations during orientation changes, as well as minimum positioning time and static compliance. The breadth of this list matters: performance cannot be reduced to a single indicator.
These parameters describe different aspects. A figure for the position reached does not directly answer how a robot follows a path; similarly, a velocity value is not equivalent to a stabilization-time value. First identify the characteristic being evaluated, then ask whether it matches what the task requires. Rather than looking for an overall rating, it is more useful to select the value that answers the specific technical question and check how it was obtained.
The list itself helps prevent an overly broad reading of a figure. If the interest is in a path characteristic, for example, a pose value does not directly describe it; if the aim is to understand stabilization time, a velocity value is not a substitute. This does not mean one parameter is more important than another in every case: its usefulness depends on the question being asked. Selection should start with the task, not with whichever figure is most prominent on the datasheet.
Accuracy and repeatability are not synonyms
The standard distinguishes pose accuracy from pose repeatability, among other characteristics. As a guide to reading a datasheet, accuracy concerns the relationship between the target pose and the measured pose; repeatability concerns the consistency of results when returning to a pose in a defined test. This conceptual distinction helps frame questions, but does not replace the formal definitions or complete procedures in ISO 9283, whose full text has not been verified for this article.
A consistent result does not, by itself, prove that the achieved position exactly matches the desired one. Likewise, a favourable accuracy figure does not let us infer how the robot will behave across all repetitions or while following a path. Do not use “accuracy” and “repeatability” as equivalents, or treat either as an automatic summary of the others. When assessing a specification, ask separately how the measured pose relates to the target and how much consistency the reported test reflects.
In other words, the two questions complement each other but are not interchangeable: one concerns the relationship between the target and the measurement, while the other concerns the consistency observed on repetition under the test conditions. Looking at only one figure leaves the other question unanswered. This explanation is a conceptual guide to interpreting a datasheet, not a complete normative definition or an account of how to calculate each parameter.
The test and its conditions matter
The available documentation indicates that tests covered by ISO 9283 may be applied in whole or in part, and that the user selects the characteristics to evaluate according to their requirements. A datasheet may therefore show only some of the possible parameters. The absence of a figure does not, on its own, mean that the robot obtained an unfavourable result: that characteristic may not have been tested or published.
The evidence consulted is not enough to describe every configuration, stage, and condition required by each procedure in the standard. It would therefore be irresponsible to offer a complete measurement recipe here. When requesting comparable data, ask for the cited edition, the parameter, the tests performed, and the conditions documented by the manufacturer or laboratory. Without that context, a figure may still prompt a useful enquiry, but should not be treated as a conclusive comparison.
Requesting those details does not mean dismissing a briefly presented specification. It helps clarify what the figure represents and how far it can be used in a comparison. It also separates what is known—the published value—from what still needs clarification, such as the exact parameter or reported conditions. When comparing more than one datasheet, this context makes it possible to assess whether the results are of the same kind, rather than merely two numbers that look similar.
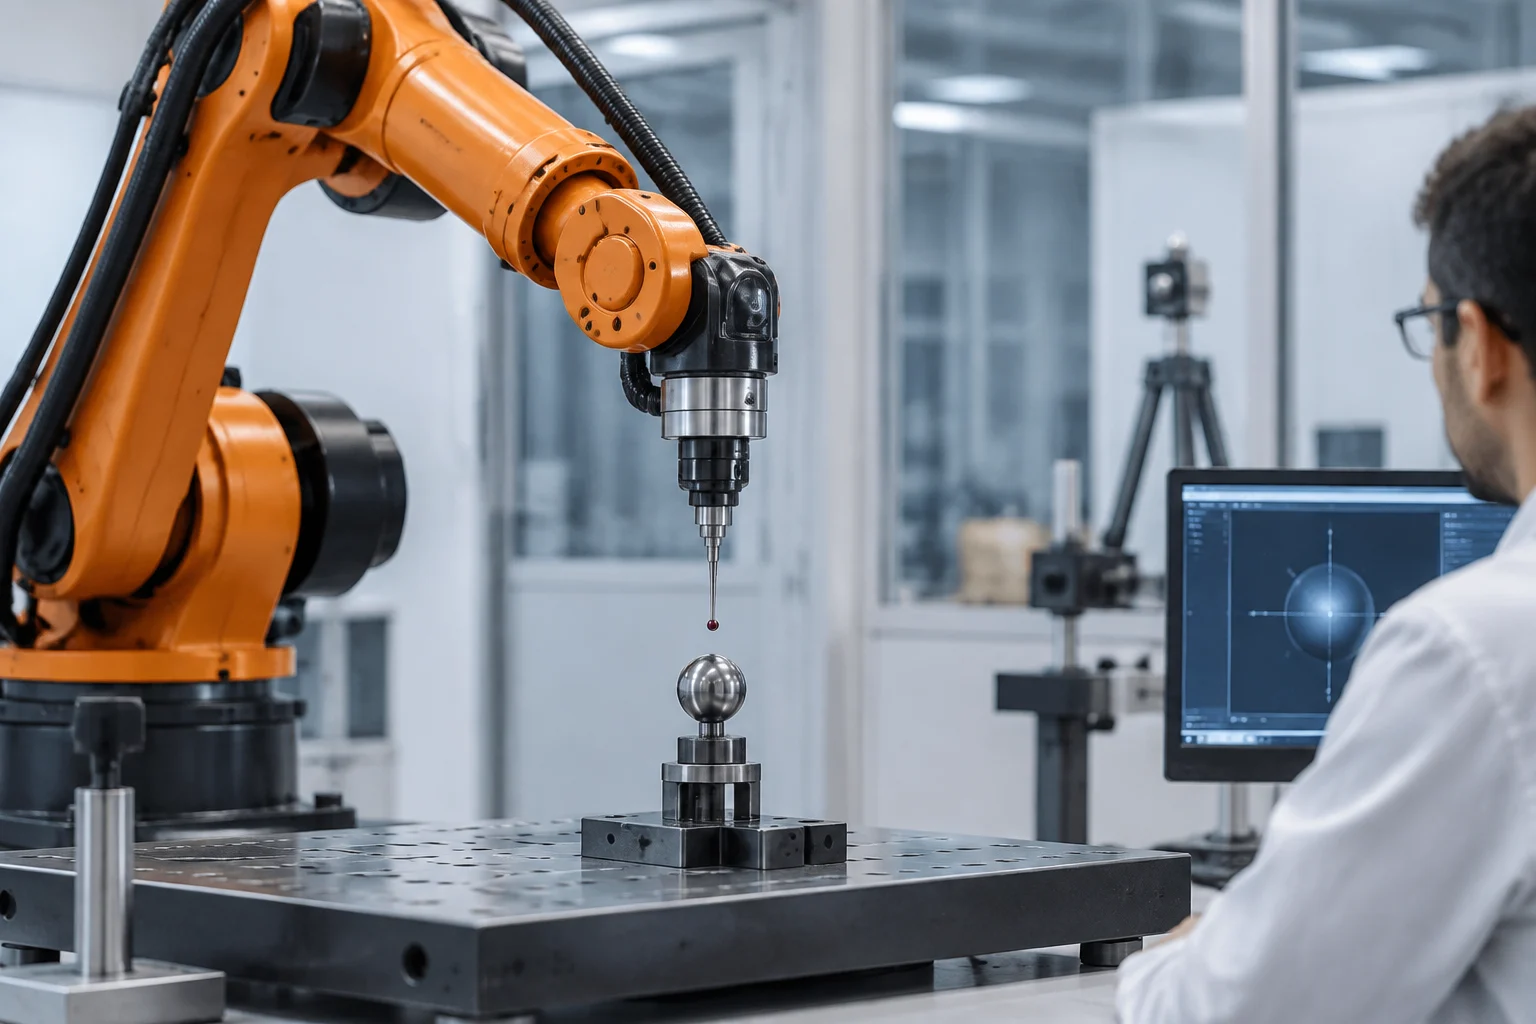
What a standardized measurement does not prove
A measurement of a manipulator’s characteristics is not automatically a guarantee about the outcome of a complete industrial cell. The scope described for ISO 9283 concerns manipulating robots. In presenting ISO 18646-2 on service robot navigation, ISO distinguishes the scope of mobile platforms and notes that ISO 9283 applies to evaluating manipulator characteristics. This reference helps define the respective scopes; it does not, by itself, prove how a particular installation will perform.
Consequently, citing a standardized test is not enough to claim that a specific assembly, welding, or handling operation will meet a production target. Assessing that conclusion requires task-related criteria and data that make it possible to verify performance in the relevant context. In practice, the standard can structure a conversation with a supplier and support more precise questions; it does not replace validation of the real application or turn a measured result into a universal promise.
The distinction matters because a particular cell and task are not described by a single manipulator characteristic. A measurement can provide information about the parameter tested, but a conclusion about production results requires evidence relevant to that application. The standard is therefore useful for clarifying what is being evaluated and structuring the technical discussion, provided it is not given a broader scope than stated.
A checklist for reading datasheets
Before comparing two models, confirm that the figures refer to the same parameter: for example, pose repeatability versus pose repeatability, not pose repeatability versus path accuracy. Also check which edition of ISO 9283 is cited and which tests were performed. If a specification omits those details, treat it as missing context for deciding whether the values are directly comparable. The figure may still be useful as a starting point, but it does not answer every performance question on its own.
Next, match the parameter to the process requirement and review the reported conditions. For a task that depends on the path, a pose value does not directly answer the question; to assess a return to a position, a path indicator is not a direct substitute either. As a practical check, request the relevant characteristic, test reference, and published conditions; identify what was measured and what was not. This avoids reading a partial result as if it described the robot in every situation.
In practice, the review can follow a short sequence: identify the parameter, check the cited edition, find out which test was carried out, and review the documented conditions. Then compare only data that answer the same technical question and assess whether that question matters to the task. If information is missing, request it before drawing a conclusion. The goal is not to collect more figures, but to understand clearly what each one supports—and what falls outside its scope.