The Role of Connectivity in Collaborative Robotics
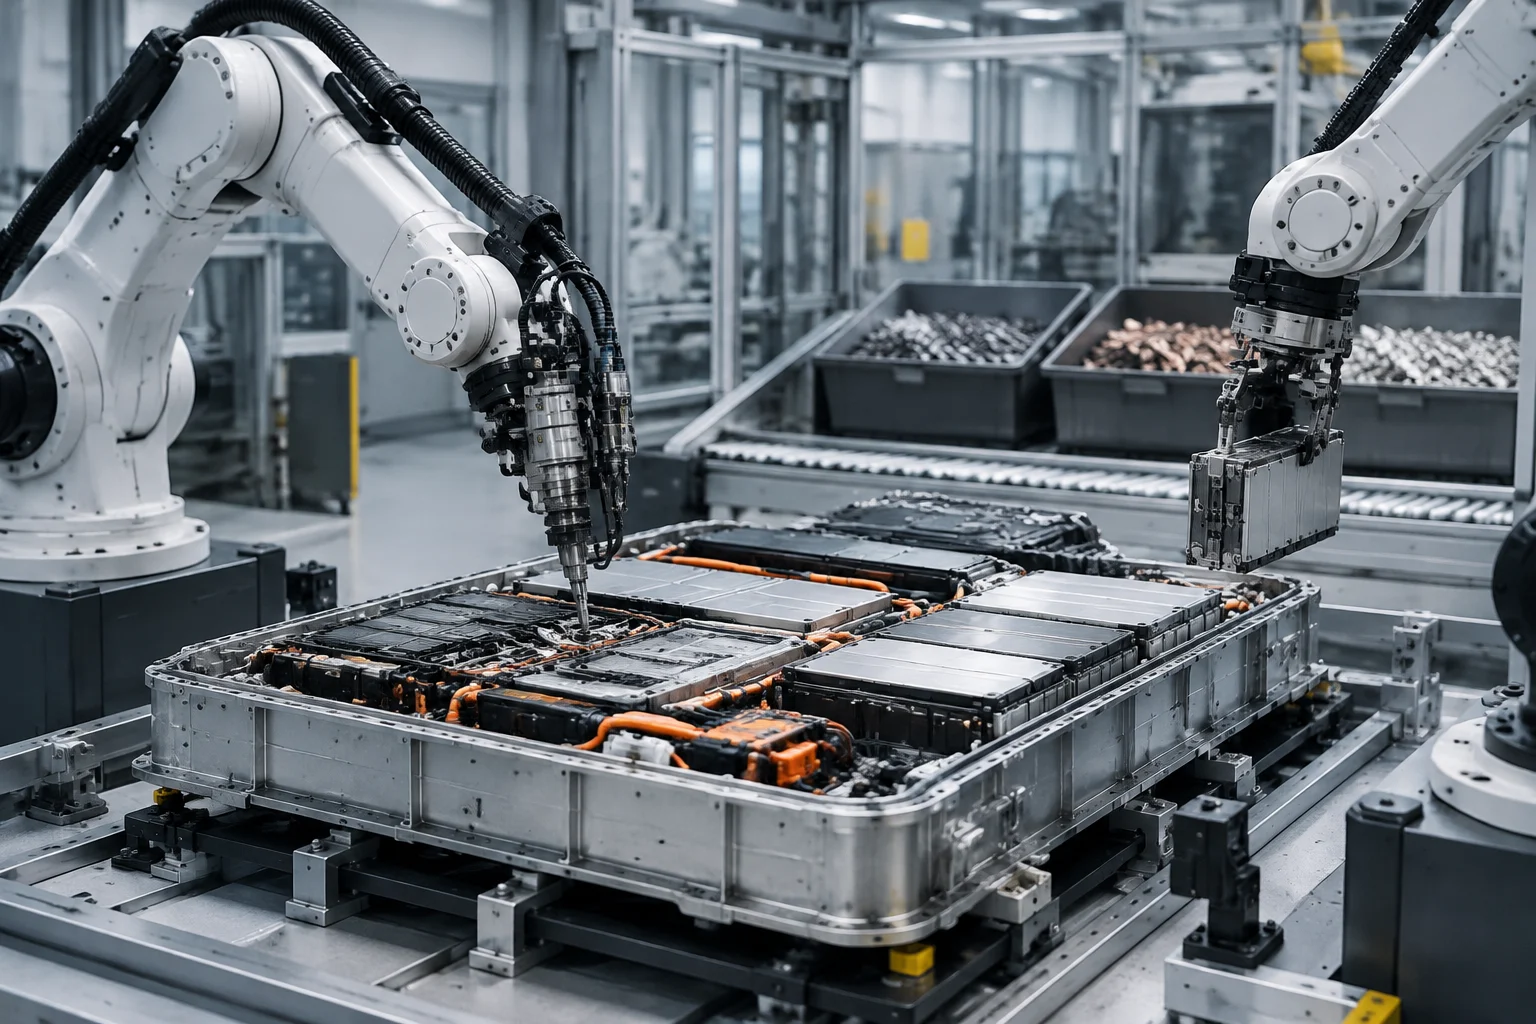
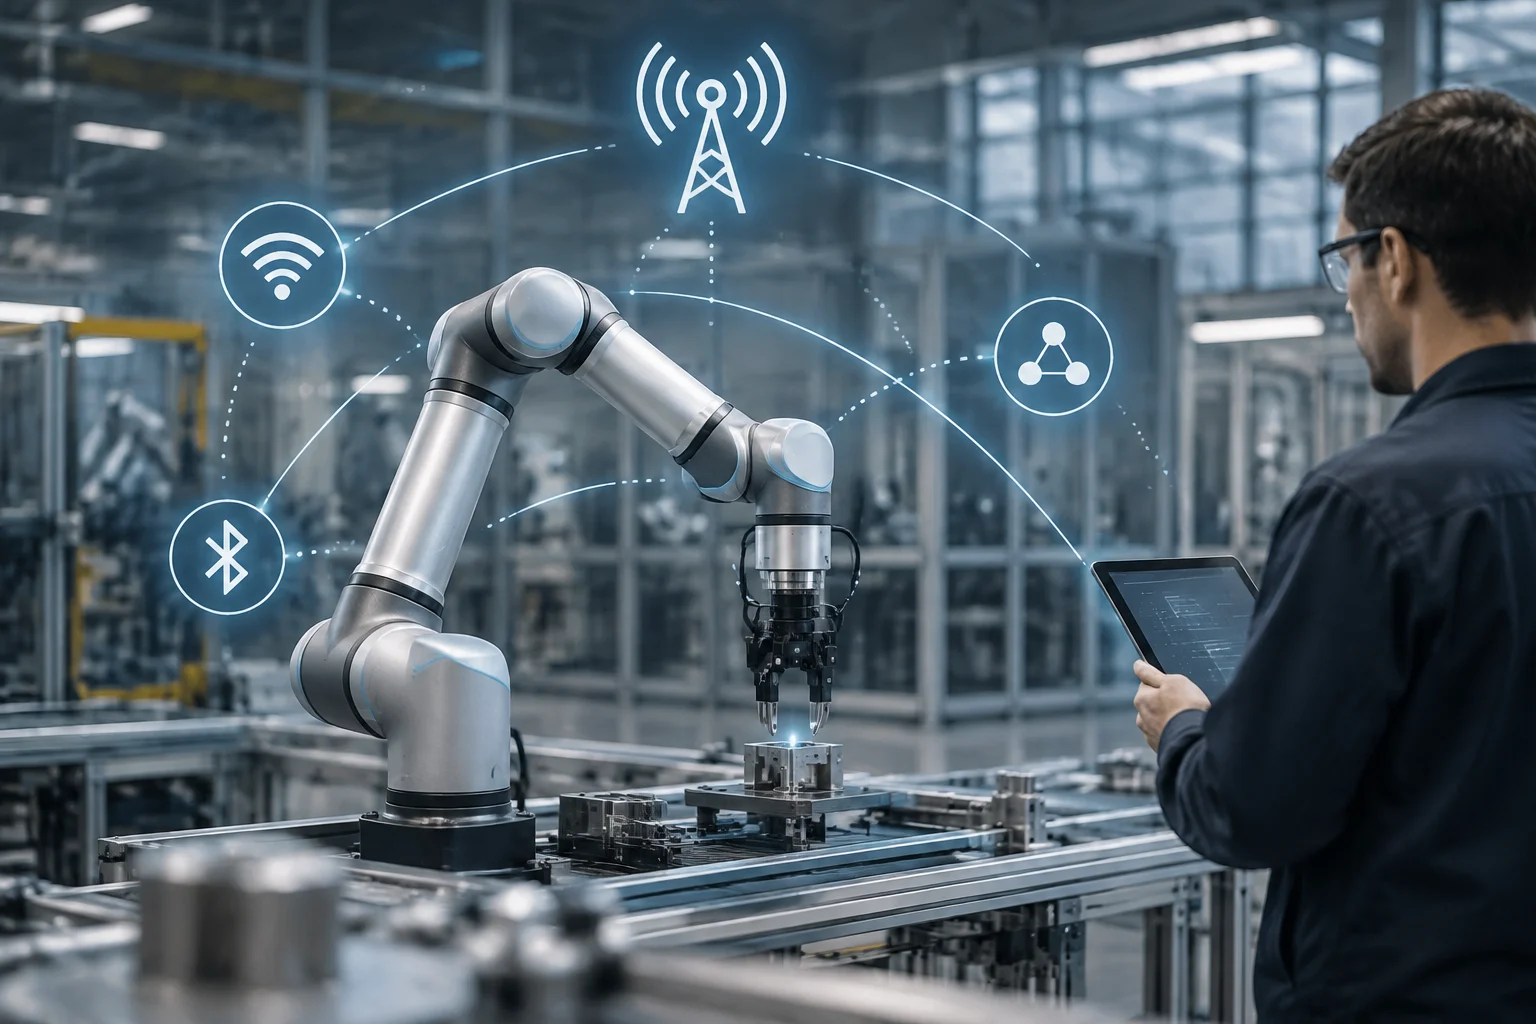
Collaborative robotics has evolved from isolated arms into systems that interact directly with operators and other robots. This integration demands a robust communication layer enabling real-time data exchange, movement coordination, and safety management. Unlike traditional robotics, where control is local and wired, modern cobots rely on networks supporting both control commands and sensor telemetry.
According to Eurecat, 85% of repetitive tasks in industry and logistics could be automated with currently available technology. However, the barrier is not just hardware, but the capacity for interoperability between heterogeneous devices. Autonomous mobile robots, for instance, use SLAM to map their environment, but they need to transmit these maps and states to a central platform or other robots to avoid collisions and optimize routes.
This constant communication need redefines the plant architecture. It is not just about moving an arm, but orchestrating an ecosystem where every node, from a force sensor to a mobile robot, shares critical information. The reliability of this exchange determines operator safety and the efficiency of the production process.
Industrial Control Protocols vs. Field Connectivity
It is fundamental to distinguish between motion control protocols and field connectivity protocols. Universal Robots, a leading cobot manufacturer, uses protocols like Profinet, EtherNet/IP, TCP/IP, and Modbus for direct communication with controllers and PLCs. These protocols guarantee the determinism and low latency required for the kinematic control of the robotic arm.
On the other hand, field connectivity, which manages sensors, auxiliary actuators, and telemetry, usually relies on short-range wireless technologies. This is where Bluetooth Low Energy (BLE) and ZigBee come into play. While arm control requires a dedicated and often wired network to ensure safety, vibration, temperature, or position telemetry can be transmitted via BLE, reducing cabling and facilitating predictive maintenance.
Separating these layers allows resource optimization. Industrial cabling ensures precision in control, while wireless adds flexibility in monitoring. This duality is key to balancing the technical rigidity of control with the adaptability of field sensors.
Bluetooth Low Energy: Autonomy and Sensors
Bluetooth LE is the dominant technology for sensor connectivity in industrial environments due to its low power consumption. Introduced in the Bluetooth 4.0 specification, it allows devices to operate for years on a single battery, which is critical for sensors mounted on moving parts of a robot or in portable tools interacting with the cobot.
In collaborative robotics applications, BLE is used to transmit tool status data, QR codes for part identification, or proximity signals for human presence detection. Its limited range (typically 10-100 meters) is an advantage in production plants, as it reduces interference with other systems and allows natural network segmentation by work zones.
The autonomy of BLE, which can reach between 2 and 5 years depending on transmission frequency, eliminates the need for frequent maintenance in remote sensors. This is especially useful in environments where battery access is difficult or where industrial dirt could affect physical connections.
ZigBee and Mesh Networks for Industrial IoT
ZigBee offers an alternative to BLE when a more extensive and robust mesh network is required. Unlike BLE, which usually operates in star or point-to-point topology, ZigBee allows nodes to retransmit the signal, extending coverage and improving redundancy. This is useful in large industrial warehouses where a single access point does not cover the entire robot operation area.
The standardization of ZigBee by the Connectivity Standards Alliance guarantees interoperability between devices from different manufacturers. For a robotics systems integrator, this means combining sensors from one supplier with gateways from another, provided both comply with the ZigBee specification. Backward compatibility is a key factor for protecting long-term investments in industrial IoT infrastructure.
ZigBee's mesh architecture provides superior resilience against individual node failures. If a sensor loses direct connection with the gateway, the network automatically reconfigures through other nodes, ensuring the continuity of real-time data flow.
5G and URLLC: The Leap Towards Autonomous Mobility
For autonomous mobile robots (AMR) moving across the entire plant, short-range technologies like BLE or ZigBee may be insufficient due to their limited range and the need for handover between cells. Here, 5G emerges as the key enabling technology, specifically through the URLLC (Ultra Reliable Low Latency Communication) functionality.
The requirements for a robot to operate safely and smoothly via wireless communication are strict: packet transmission latency must be less than 1 millisecond, and the probability of packet loss must be 1 in 100,000. These performance levels, previously only achievable with wired Ethernet, are attainable with private 5G. This allows mobile robots to maintain perfect synchronization with the cloud or other robots, even at high speed and in highly interfered environments.
Uninterrupted mobility is the main benefit of 5G URLLC. Unlike Wi-Fi, which can suffer coverage degradation when moving between cells, 5G offers a smooth and predictable transition, essential for autonomous navigation in large and dynamic spaces.
Practical Decisions for Implementation
Protocol choice is not binary; most modern installations use a hybrid approach. Robotic arm control remains on wired industrial networks (Profinet/EtherNet/IP) to guarantee functional safety. Sensor telemetry is managed via BLE or ZigBee to reduce cabling costs. And AMR mobility is supported by 5G or high-density Wi-Fi 6.
When planning infrastructure, engineers must consider the electromagnetic interference inherent in industrial plants. High-voltage motors and frequency inverters generate noise that can affect 2.4 GHz signals (used by BLE, ZigBee, and Wi-Fi). Therefore, it is recommended to conduct a radio spectrum study before deploying the network and consider using Sub-GHz bands for ZigBee in environments with high density of 2.4 GHz devices.
Prior planning is crucial to avoid signal conflicts. A detailed analysis of the environment allows selecting the right frequencies and positioning access points optimally, ensuring the wireless network does not become a weak point in robotic operations.